ROS2 MCP


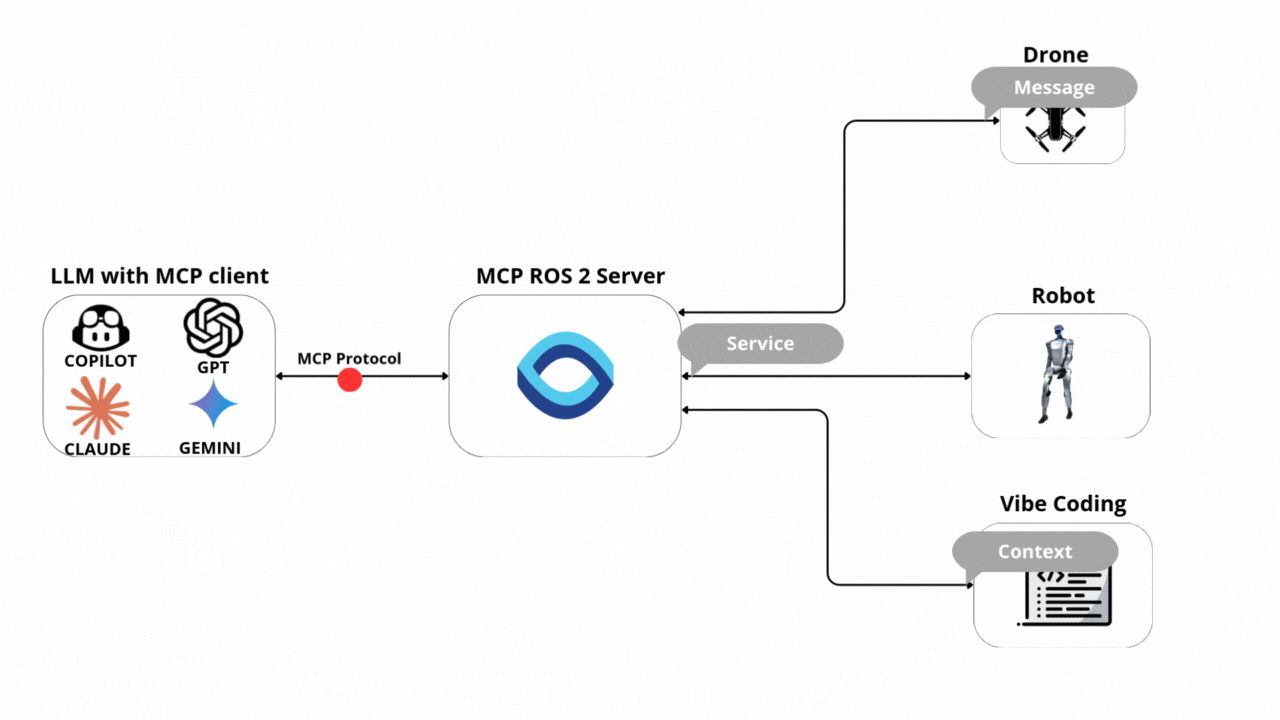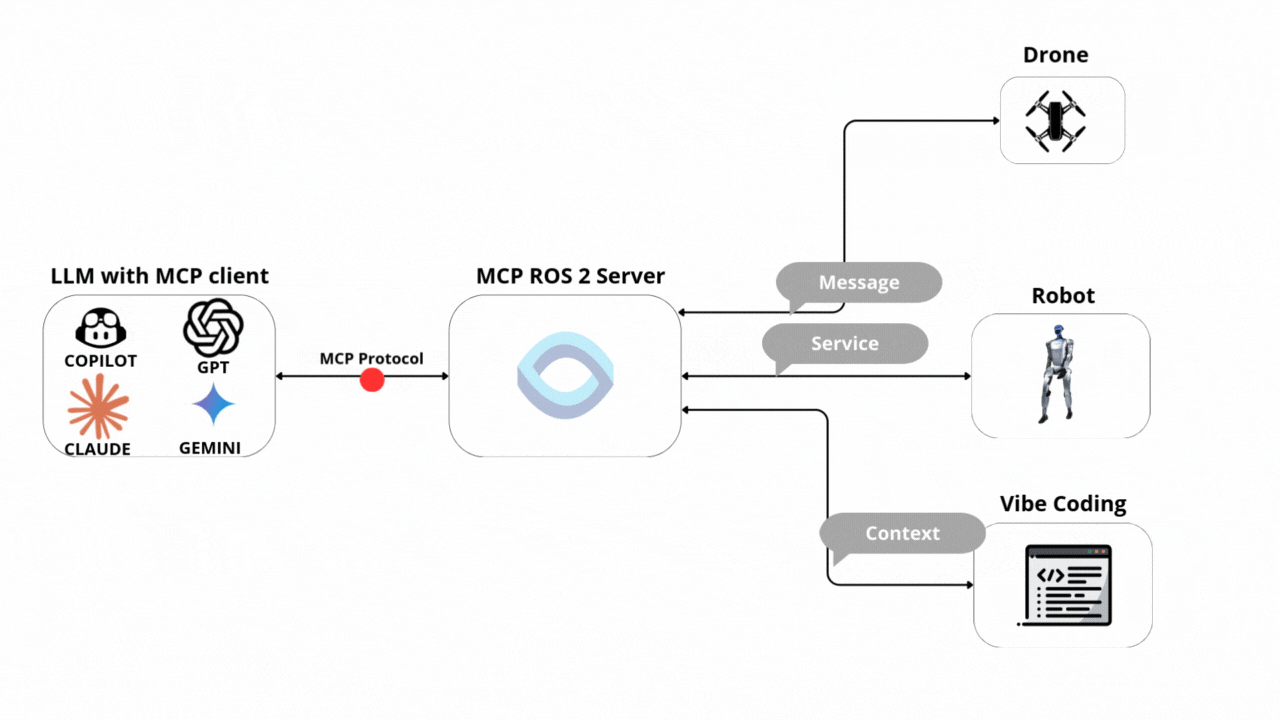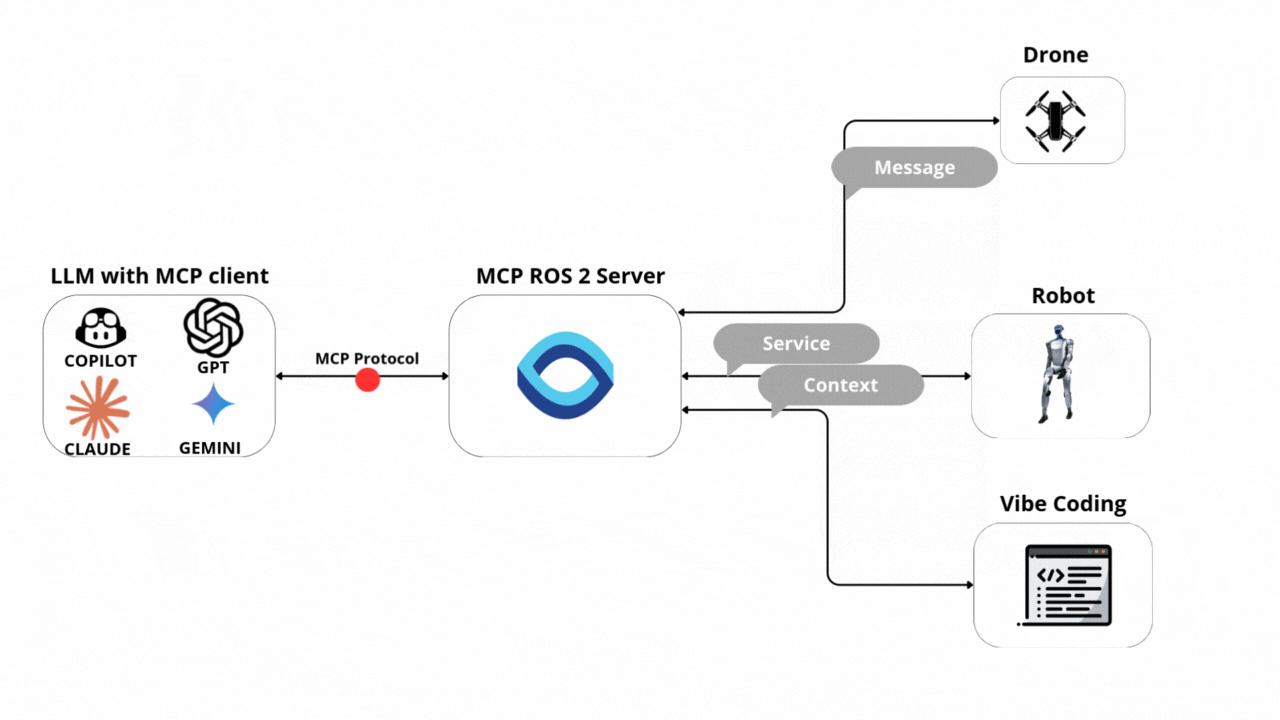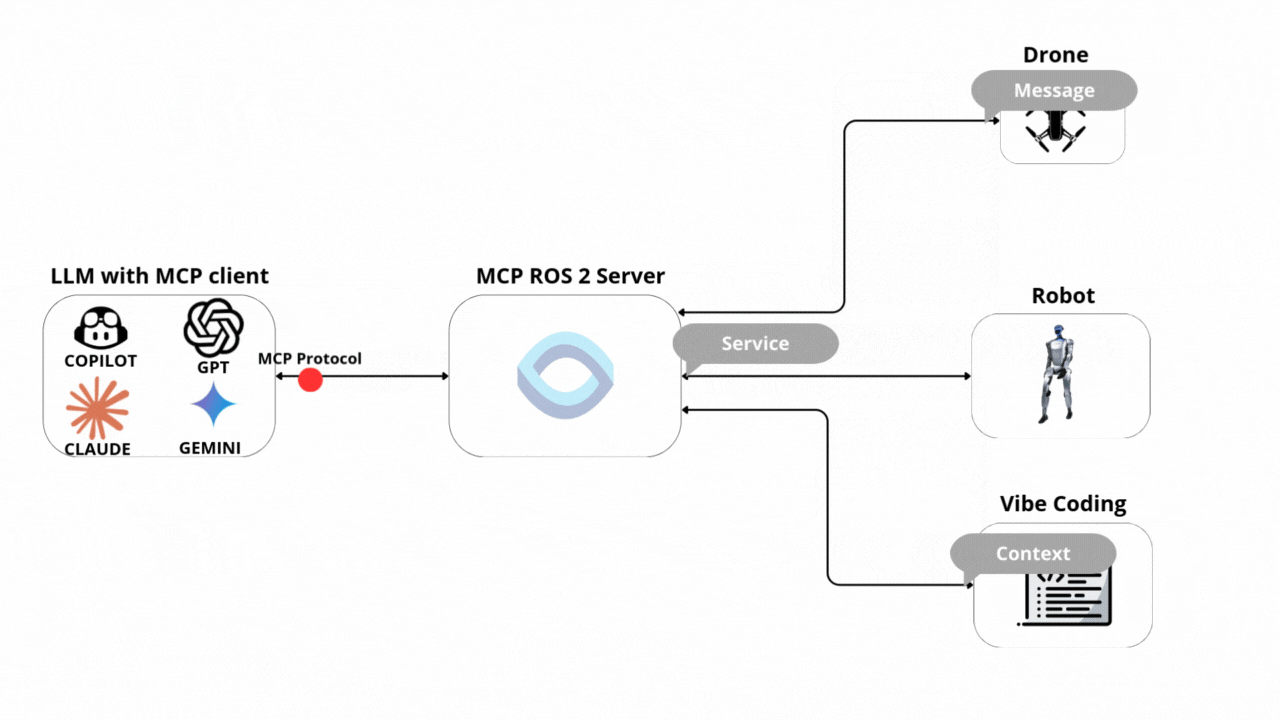
ROS2 MCP is an open-source (MPL-2.0) Model Context Protocol (MCP) server for ROS 2 Humble and Jazzy, written in Python. It lets AI tools such as Claude, Cursor and Codex list, subscribe to, publish on and call ROS 2 topics, services and actions over stdio (or SSE). It is listed in Docker's official MCP catalog as mcp/ros2.
Every tool is free and open source, including multi-topic subscribe/publish, map-to-image and point-cloud bird's-eye view.
🌐 Website: wisevision.tech · 📚 Documentation: wisevision.tech/docs
🔒 Security: read-only mode
An agent connected to a real robot can move it. Start the server in read-only mode to let the agent observe but not act:
ROS2_MCP_READONLY=1 uv run mcp_ros_2_server      # env var
uv run mcp_ros_2_server --read-only              # or CLI flag
docker run -i --rm -e ROS2_MCP_READONLY=1 mcp/ros2
In read-only mode the tools that change robot state are not registered at all: they do not appear in list_tools, and calling one returns an Unknown tool error. The hidden tools are:
ros2_topic_publish, ros2_publish_multiple_topics, ros2_service_call, ros2_send_action_goal, ros2_cancel_action_goal.
Read-only mode fails closed: only tools that were explicitly reviewed as read-only (listed in server/tool_safety.py) are registered, and a test fails if a new tool is added without being classified.
ros2_service_call is hidden because the server cannot know whether an arbitrary service has side effects.
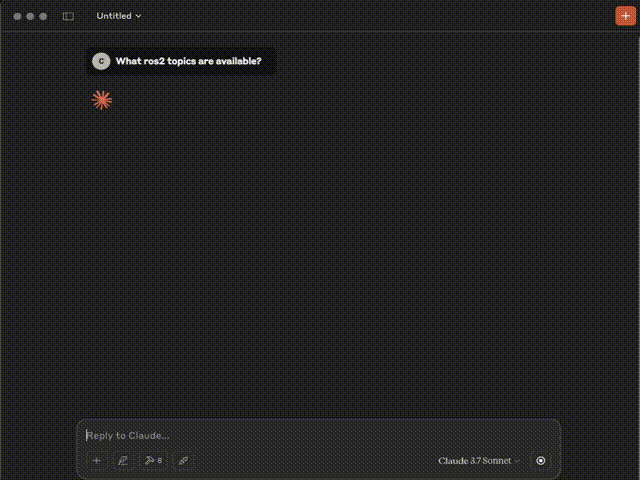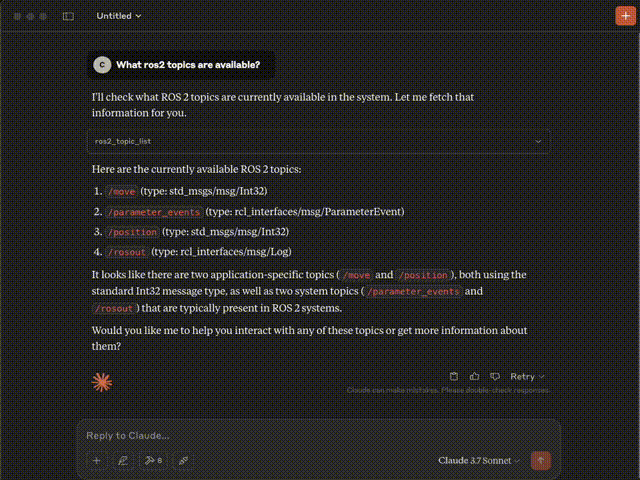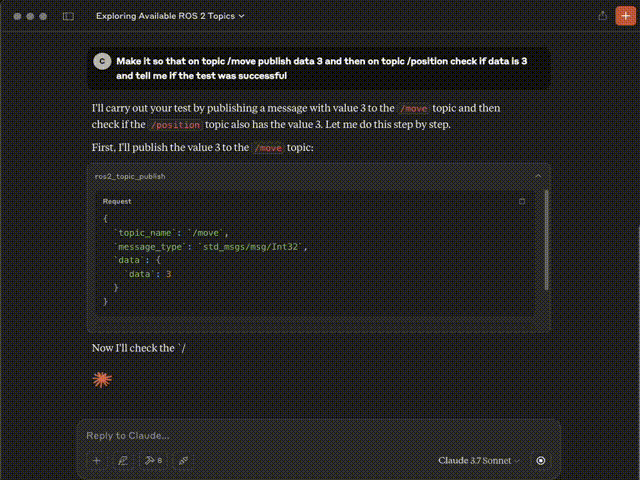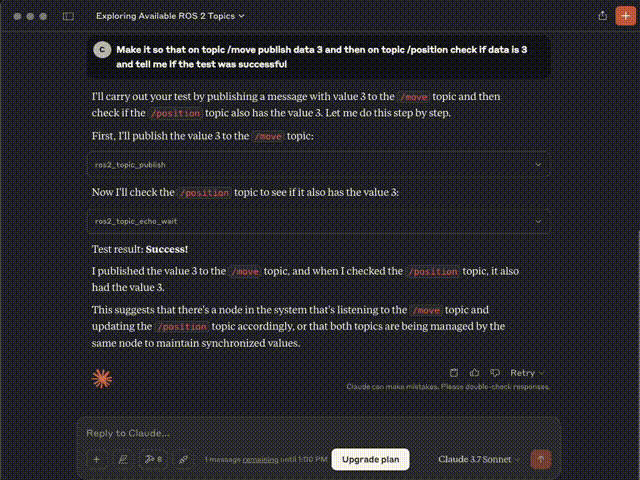
- List available topics
- List available services
- Lists available actions with their types and request fields
- Call services
- Subscribe to topics to collect messages
- Publish messages to topics
- Echo messages on topics
- Get fields from message types
- Sends an action goal and optionally waits for the result
- Requests the result of an action goal
- Subscribes to feedback messages from an action
- Subscribes to status updates of an action
- Cancels a specific goal or all active goals
- Get messages from WiseVision Data Black Box (InfluxDB alternative to Rosbag2)
- Subscribe to several topics at once (images returned as PNG)
- Publish to several topics at once at a set frequency and duration
- Get a
nav_msgs/OccupancyGrid map as a PNG image
- Get a
sensor_msgs/PointCloud2 as a bird's-eye-view PNG image
🤖 Available Prompts
📊 base.ros2-topic-echo-and-analyze
Subscribe to a ROS2 topic, collect messages for a specified duration, and provide statistical analysis of the collected data.
➡️ Can auto-detect topic if only one is available. Analyzes message rates, counts, and statistics on numeric fields.
🔄 base.ros2-topic-relay
Subscribe to one ROS2 topic and republish messages to another topic with optional transformations.
➡️ Supports identity relay, rate limiting, and change-based filtering.
🏥 base.ros2-node-health-check
Check if expected ROS2 topics and services are available and functioning correctly with optional publication rate monitoring.
➡️ Provides comprehensive health report with status indicators and recommendations.
🔍 base.ros2-topic-diff-monitor
Compare two ROS2 topics and report differences in their messages with detailed field-by-field analysis.
➡️ Useful for comparing raw sensor data with filtered/processed versions or verifying topic synchronization.
Note: To call a service with a custom (non-default) type, source the package that defines it before starting the server.
🎯 Why Choose This MCP Server?
Save hours of development time with native AI integration for your ROS 2 projects:
Why this ROS 2 MCP server ⭐
- ⚡ 1-minute setup - one
docker run or uv run command
- 0️⃣ Zero-friction setup - stdio transport, no brokers, no webserver.
- 🔌 Auto type discovery - a built-in “list interfaces” tool dynamically enumerates available topics and services together with their message/service definitions (fields, types, schema) — so the client always knows exactly what data can be published or called.
- ✨ Nested field support: Handle complex message structures with ease.
- 🤖 AI-powered debugging - Let AI help you troubleshoot ROS 2 issues in real time
- 📊 Smart data analysis - Query your robot's sensor data using natural language
- 🚀 Boost productivity - Control robots, analyze logs, and debug issues through AI chat
- 💡 No ROS 2 expertise required - AI translates your requests into proper ROS 2 commands
- 🐋 Dockerized: Ready-to-use Docker image for quick deployment.
- 🔧 Auto QoS selection: Automatically selects appropriate Quality of Service settings for topics and services, ensuring optimal communication performance without manual configuration.
Perfect for: Robotics developers, researchers, students, and anyone working with ROS 2 who wants to leverage AI for faster development and debugging.
🚀 Enjoying this project?
Feel free to contribute or reach out for support! Write issues, submit PRs, or join our Discord community to connect with other ROS 2 and AI enthusiasts.
Want to see it on real data? The
forklift rosbag demo replays a
warehouse forklift recording and walks through three MCP calls in about ten
minutes.
🤝 Contributing
Contributions are welcome! Please check the open issues for
ways to help, open a pull request, or drop by our Discord to discuss ideas
before diving in. By participating, you agree to follow our Code of Conduct.
🚀 Drone Mission Using Prompts
🌍 Real-world examples:
⚙️ Installation
Follow the installation guide for step-by-step instructions:
🧭 DDS discovery warm-up (Docker)
If the first tool call returns an incomplete list of topics/services right after container start, DDS discovery may still be in progress.
The server performs a one-time warm-up on the first tool call in container environments; tune it via:
MCP_ROS_DISCOVERY_STABLE_SEC (default: 1.0)MCP_ROS_DISCOVERY_TIMEOUT_SEC (default: 5.0)MCP_ROS_DISCOVERY_WARMUP=false to disable
💡 Want to try it in simulation?
Check out the Gazebo Drone Demo section
📋 Topics
🛠 Services
🎯 Actions
🐞 Debugging
Since MCP servers run over stdio, debugging can be challenging. For the best debugging
experience, we strongly recommend using the MCP Inspector.
You can launch the MCP Inspector via npm with this command:
npx @modelcontextprotocol/inspector uv --directory /path/to/ros2_mcp run mcp_ros_2_server
Upon launching, the Inspector will display a URL that you can access in your browser to begin debugging.
📚 Origins and evolution
We built this server to make AI‑assisted ROS 2 development fast and reliable. Internally, we needed a simple way for agents to discover message types, publish/subscribe to topics, and call services—without boilerplate or flaky networking. That led to a few core design goals:
- Handle all ROS 2 message types (including nested fields) so agents can write and test any code
- Integrate topic pub/sub and service calls to validate behavior end‑to‑end
- Work seamlessly with GitHub Copilot in VS Code and other MCP clients
- Use a simple stdio transport to avoid network complexity
After dogfooding it, we open‑sourced the project (MPL-2.0) to help the broader ROS 2 community build faster with AI. It’s now useful not only for development, but also for controlling robots, running QoS experiments, and analyzing live data and robot/swarm state. The project is actively maintained—features and improvements ship regularly based on user feedback. If this project helps you, share your use case in Discussions!




